
AV2.0
Driving intelligence that generalizes at scale
Our pioneering approach to end-to-end driving is designed to generalize across cities, vehicles, sensors, and driving environments.
What is AV2.0?
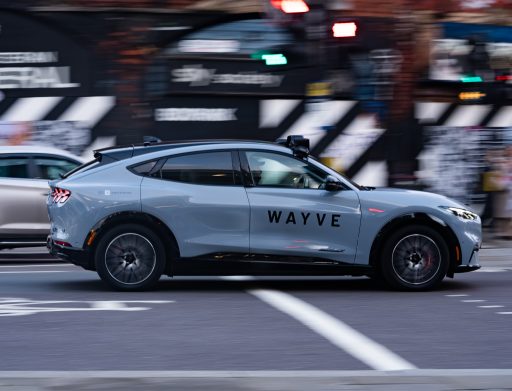
At Wayve, our mission is to reimagine autonomous mobility through embodied intelligence. Our solution uses deep learning to solve the challenges of self-driving, eliminating the need for expensive and complex robotic stacks that require highly-detailed maps and programmed rules. The result is a end-to-end solution that learns from experience to drive in any environment. We call this next generation AI-centric approach AV2.0.
AV2.0 vs. AV1.0
The traditional AV1.0 approach relies on hand-engineered stacks, HD maps and a rule-based approach – this limits scalability and the ability to rapidly generalize to new environments or complex scenarios. Wayve’s AV2.0 takes a different path – a single, learned AI driver trained to understand the world, anticipate risk, and adapt to new environments
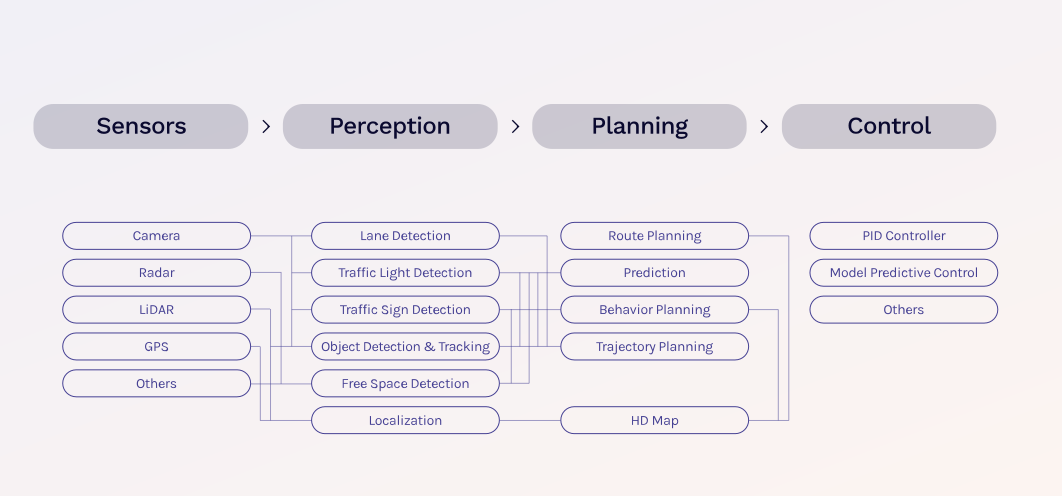
AV1.0
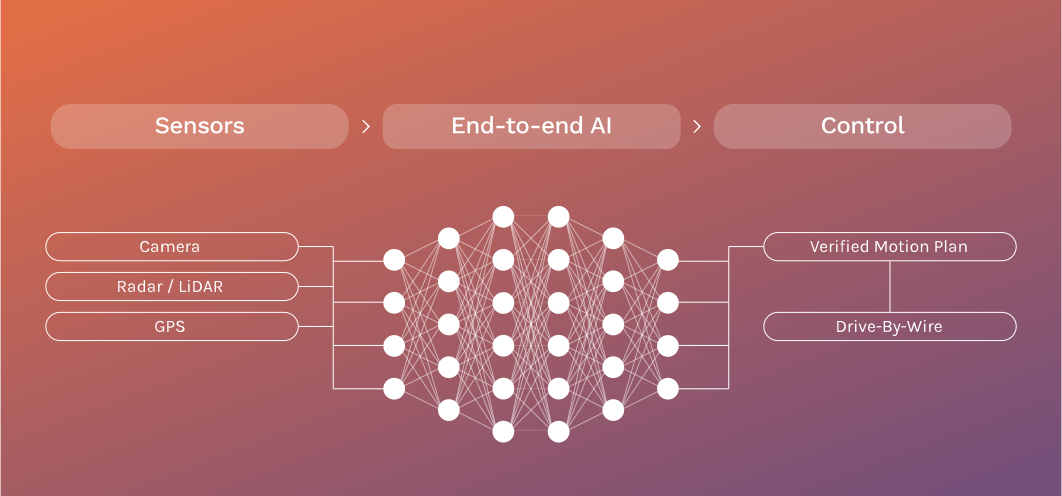
AV2.0
Global Roadtrip
Generalization through AV2.0
AV2.0 moves autonomy beyond city-by-city deployment, enabling deployment to cities around the world with little to no prior experience.
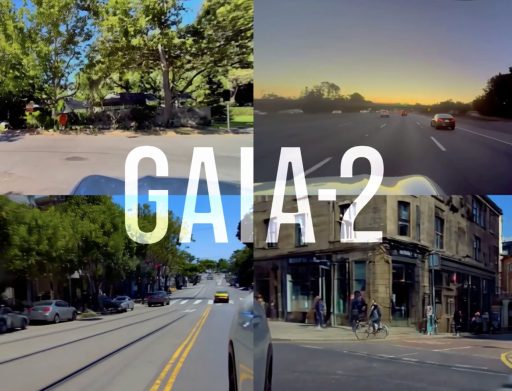
The Global Road Trip showed what AV2.0 is designed to unlock: autonomy that can travel beyond a single city, route, or operating domain. By driving across many cities, countries, road types, and conditions, AV2.0 demonstrates a path toward systems that generalize across the real world.
Safety 2.0
Building a safe driving intelligence
AV2.0 requires a new approach to safety – one that addresses safety through deep world understanding.
Unlike traditional methods, Safety 2.0 acknowledges that true safety comes from an AI that interprets the driving environment naturally, like a human driver. It establishes an AI system that inherently comprehends the intricacies of the world and driving behaviors, which it uses to navigate safely. This revolutionary approach solves the long-tail of real world complexity and aligns with critical safety principles, including redundancy, fail-operational behaviors, and adherence to automotive safety standards such as ISO 26262 and SOTIF.
Teaching cars to drive with deep learning
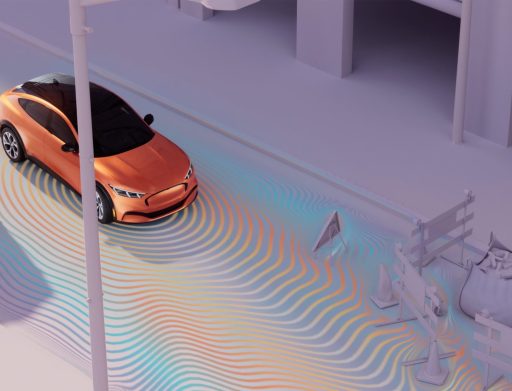
Deep learning has achieved significant breakthroughs in solving many complex decision-making problems. At Wayve, we are using deep learning to train our AI software to recognize and predict how people and objects will move around the vehicle and to reason the best path forward.
Our data-driven AI Driver can convert data inputs from cameras and radar into driving outputs, like turning the wheel or slowing down, seamlessly through one neural network that’s thoroughly tested for performance and safety and robustly integrated into a base vehicle.
AV2.0