
Technology
Pioneering a new way to solve self-driving with Embodied AI
Safe, scalable driving automation through Embodied AI
Wayve specializes in developing AI foundation models for autonomous driving. Our technology equips vehicles with a ‘robot brain’ that can learn from and interact with real-world environments.
Optimized for safe driving
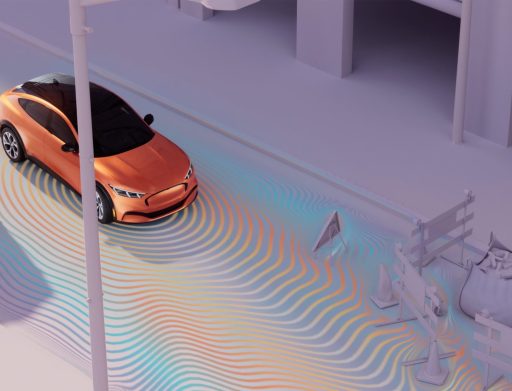
Embodied AI uses a domain-optimized model architecture that prioritizes automotive safety, resulting in safe and natural driving performance.
Solves the long-tail problem
Embodied AI has superior generalization capabilities, allowing it to applying ‘learned’ driving skills to unexpected scenarios, even without prior training exposure.
Efficient and large-scale learning
Our self-supervised learning method enables efficient, large-scale learning, essential for seamlessly adapting AI capabilities to new vehicles and geographies.
Pioneering the end-to-end AI Driving Model
Wayve's AV2.0 Approach
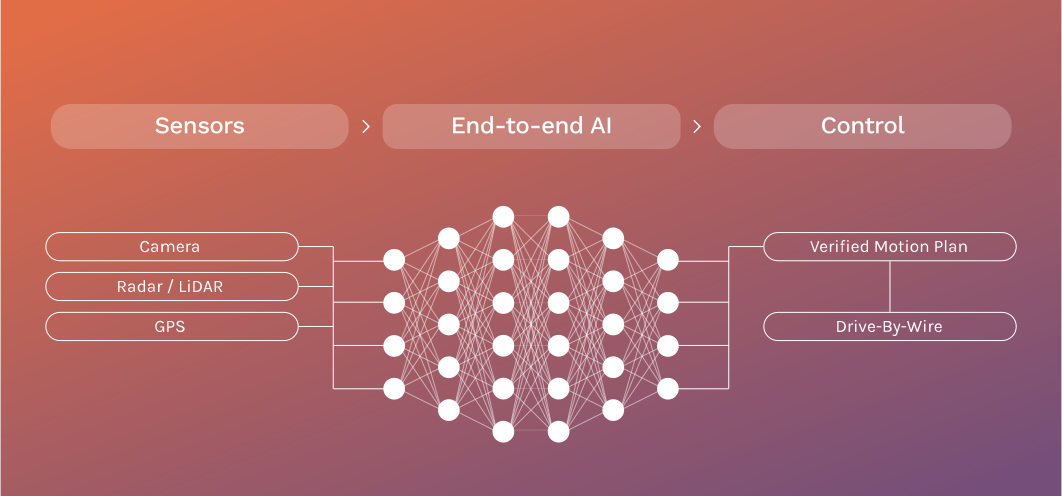
Our innovative approach replaces the modular ‘sense-plan-act’ architecture of the traditional AV1.0 approach with a single neural network trained on diverse data to convert raw sensor inputs into safe driving outputs.
AV2.0
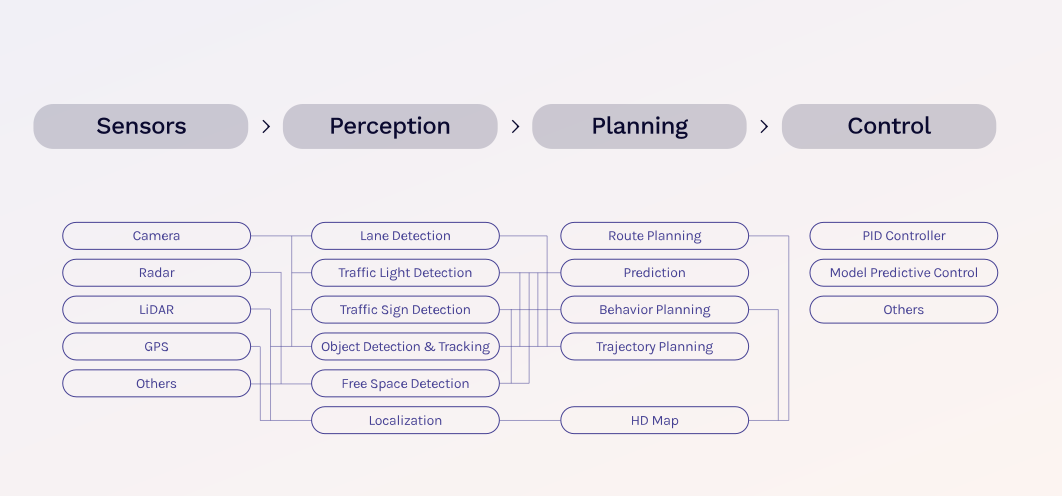
AV1.0
Advantages of Wayve’s AV2.0 approach
Eliminates labeled data
AV2.0 learns driving skills from raw, unlabeled data using self-supervised learning, which eliminates the need to curate expensive and time-consuming labeled datasets.
Lean sensor suite
AV2.0 allows us to think differently about sensors. This data-first approach is flexible to sensor selection, giving OEMs the freedom to choose hardware based on their needs.
Mapless autonomy
AV2.0 doesn’t rely on HD maps. This enables seamless expansion to new geographies through data-driven adaptations.
Vehicle agnostic
AV2.0 can adapt to operate on any type of vehicle, from passenger cars to delivery vans. Advances made on either vehicle type directly benefit the other.
AV2.0
Fleet Learning Loop
AV2.0 introduces a rapid, continuous, and seamless fleet-learning loop: recording data, training models, evaluating performance, and deploying updated models.
Advantages of Wayve’s Fleet Learning Loop
Powerful data-to-value engine
Efficiently gathers real-world driving data from diverse fleets, processes it in a cloud-based training infrastructure, and converts it into refined driving capabilities.
Builds verifiably robust performance
Optimally designed to support the transition from ‘eyes-on’ driving functions to ‘eyes-off’ as driving data exposure builds verifiably robust automated driving capabilities.
Responsible model development
Implements MLops workflows for responsible model development, utilizing innovative tools, processes, and pipelines to build, train, and deploy foundation models.
Comprehensive “off-road” evaluation
Rigorously tests our AI driving models across a vast array of simulated driving scenarios for rapid and comprehensive evaluation.
Investing in new AI capabilities and tools
AV2.0 opens the door to utilizing state-of-the-art AI for enhanced training, simulation, evaluation, and validation processes. Wayve is investing in R&D to advance these capabilities.
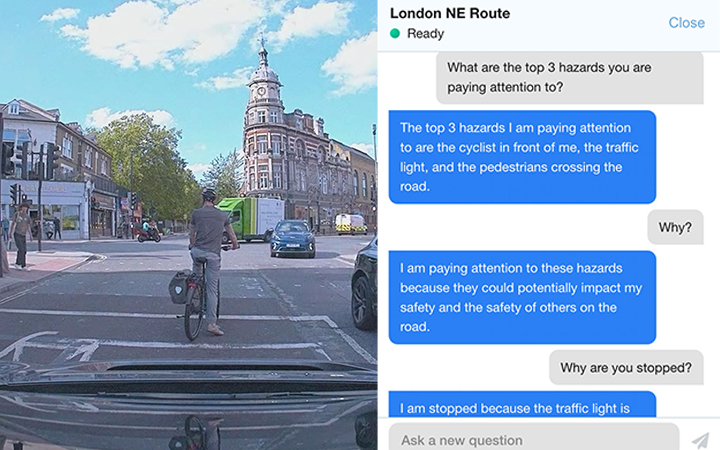
AI Explainability
LINGO-1 is a groundbreaking language model that can improve the performance and interpretability of e2e AI models by explaining the reasoning behind its driving actions, increasing transparency in their reasoning and decision-making.
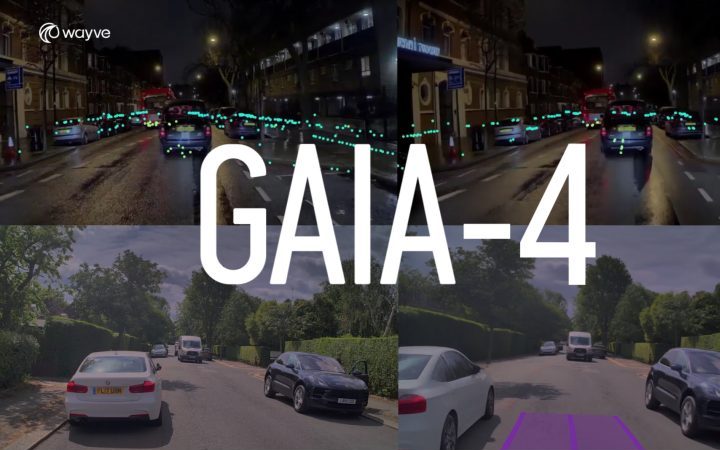
Generative AI
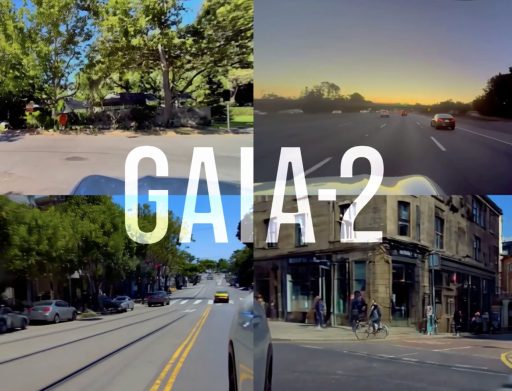
GAIA is a generative world model that predicts future events with unparalleled accuracy and generates realistic driving videos from text, action, and video prompts to accelerate training and validation, especially for edge cases.

Photorealistic Simulator
State-of-the-art neural rendering enables us to automatically generate photorealistic 4D worlds for generating thousands of simulated scenarios to train, test, and debug our AI models.
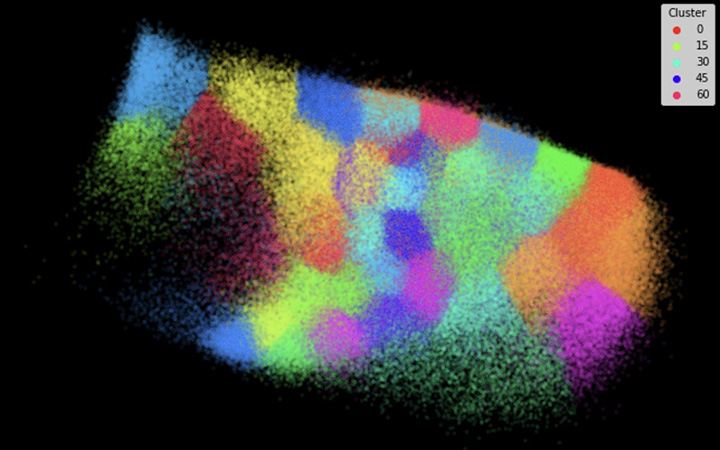
Model Introspection
Our novel Scenario Intelligence tools harness the emergent concepts generated by our e2e AI models and transform them into a framework for dataset introspection and control.

Supercomputing infrastructure for AV2.0
Wayve and Microsoft are collaborating to implement supercomputing technologies for the development of AI foundation models in autonomous vehicles.
